Field and Service Robotics

139,00 €
+ 5,99 € Envío

Field and Service Robotics
Vendido por:

139,00 €

En existencias
+ 5,99 € Envío

Política de devoluciones de 14 días

Protección al comprador

O elija un pack

Métodos de pago:

  • Marca: Unbranded

Detalles del producto

Detalles del producto

Field and Service Robotics

Mobile Robots and Smart Cars. - Mobile Manipulators: Expanding the Frontiers of Robot Applications. - Robot Navigation Inspired by Principles of Insect Vision. - Behaviour-Based Robots for Dangerous and Difficult Environments. - Towards Useful Autonomous Robotic Systems for Field and Service Applications. - Intelligent Robotics Where Are We At and Where Are We Going. - Behaviour Programmable Machines for Field Construction Operations. - Map Building and Terrain-Aided Localisation in an Underground Mine. - 3D Perception for Mining Robotics. - The Numbat: A Remotely Controlled Mine Emergency Response Vehicle. - Motion Planning and Sensor-Guided Manoeuvre Generation for an Autonomous Vehicle. - Fault Detection in the Frequency Domain: Designing Reliable Navigation Systems. - Lessons from the Development and Deployment of Dante II. - Operating Nomad During the Atacama Desert Trek. - Some Details of the Development of Mobile Robot Platforms. - Field Experiments with the Ames Marsokhod Rover. - A Case Study in Machine Intelligence: Adaptive Autonomous Space Rovers. - Navigation Data Acquisition with an Experimental Test-Bed of Planetary Exploration Rover. - Town Robot: Toward Social Interaction Technologies of Robot Systems. - Towards Autonomous Excavation. - A Mobile Robot for Training Horses. - User-Friendly Interface of Service Robot: Knowledge Projection on Robot Task Environment. - Web Telerobotics Results and Issues. - Teleoperation of Autonomous Mobile Robot Under Limited Feedback Information. - Smart Man-Machine Interfaces by Means of Projective Virtual Reality. - Using Telerobots for Recreation. - Applying Telepresence and Augmented Reality Techniques in Teleoperation of Mobile Field Robots. - Memory-Based Navigation using Omni-View Sequence. - Automation of an Industrial Fork LiftTruck Guided by Artificial Vision Ultrasonic and Infrared Sensors in Open Environments. - Robot Cleaning: An Application of Distributed Planning and Real-Time Vision. - Autonomous Mobile Robot Navigation Including Door Opening Behaviour System Integration of Mobile Manipulator to Adapt Real Environment. - Coverage Path Planning: The Boustrophedon Cellular Decomposition. - Cooperation Between Intelligent Space and Mobile Robot: Physical Agent for Intelligent Space and Extended Sensor for Mobile Robot. - Map Learning of an Office Conversant Mobile Robot JIJO-2 by Dialogue-Guided Navigation. - Robotic Sensing for the Guidance of the Visually Impaired. - Towards Terrain Aided Navigation of a Subsea Vehicle. - A Multiple-Hypothesis Approach to Concurrent Mapping and Localization for Autonomous Underwater Vehicles. - Design and Control of Underwater Wall Ranging Robot for Inspection of Nuclear Reactor. - Real Robots in an Artificial World. - An Adaptive Fuzzy-Potential Field Approach to Navigation in Dynamically Changing Environments for Practical Applications. - The GPS Aiding of INS for Land Vehicle Navigation. - The Use of Quaternions in a Low Cost Strapdown INS Unit. - The Design of a High Performance MMW Radar System for Autonomous Land Vehicle Navigation. - An Autonomous Shadow Vehicle. - Optimal Data Fusion in Decentralised Systems with Flexible Observation Rates: Estimation for a Land Vehicle. - A Gopher Robot. - Mobile Robotic Hand-Eye Co-ordination Platform: Designing and Modelling. - Monocular Vision Applied to Accurate Rov Localization. - Hunt and Gather Robotics. - Design and Implementation of Distributed Controller and its Operating System for Autonomous Mobile Robot Platform. - Vision-Based Navigation using Natural Landmarks. - On Continuous Path Tasks for a 6-DOFManipulator Mounted on a Nonholonomic Mobile Platform. - Discrete Event Control for Mobile Robots. - Hierarchical Adaptive Fuzzy Control of Mobile Robot in Dynamic Environment. - Electric Field Based Obstacle Avoidance. - Shared Discrete Event Control of a Robotic Aid for the Blind. - Evaluation of Real-Time Robot Control Systems. - Identification of Load Sway in Quay-Cranes. - Path Design and Control Algorithms for Articulated Mobile Robots. - A Practical Trajectory Following of an Articulated Steering Type Vehicle. - An Autonomous Wheelchair with a Lonworks Network Based Distribution Control System. - Utility Fusion: Map-Based Planning in a Behaviour-Based System. - A New Collision Avoidance Methodology for Multi-Robot Systems Based on the Robots' Dynamics. - Exploitation of Kinematic Redundancy in Torque-Controllable Manipulators via Multiple-Jacobian Superposition. - Toward Blind Groping: An Approach to Manipulation in Unknown Sensor-Hostile Environments. - Dynamic Simulation of Free-Flying Space Robots for Service and Exploration. - Smart End-Effector Sensing for Variable Object Handling. - Recruiting Swarm Robots Using Coded Odour Trails. - An Exploratory Robot Controller which Adapts to Unknown Environments and Damaged Sensors. - An Autonomous Blimp. - Omnidirectional Robots: New Challenges in Mobility Vision and Tactics for Robot Soccer. - Versatili
  • Marca: Unbranded
  • Categoría: Educación
  • Idioma: English
  • Fecha de publicación: 2012/01/16
  • Editor / Marca: Springer
  • Formato: Paperback
  • Nº de Fruugo : 337862238-741521272
  • ISBN: 9781447112754
Promesa

Garantía del vendedor

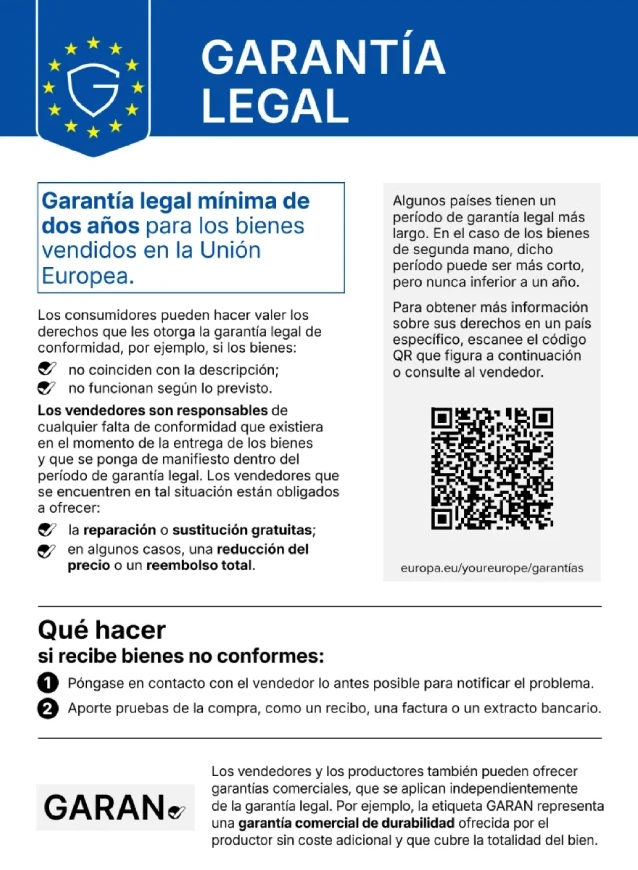
Garantía legal de 2 años incluida

Tus derechos como consumidor en la UE incluyen una garantía legal mínima gratuita de 2 años

Descargar garantía legal de conformidad
Entrega

Entrega

Enviado en un plazo de 5 días

  • STANDARD: 11,19 € - Entrega entre mar 01 diciembre 2026–vie 04 diciembre 2026

Envío desde Reino Unido.

Devoluciones

Devoluciones y cancelaciones

Devoluciones

Hacemos todo lo posible para asegurarnos de que se le entreguen los productos que pida en su totalidad y de acuerdo con sus especificaciones. Sin embargo, si recibe un pedido incompleto o artículos diferentes a los que pidió, o hay alguna otra razón por la que no está satisfecho con el pedido, puede devolver el mismo o cualquier producto incluido en él y obtener un reembolso completo por los artículos.

Vea la política de devolución completa

Cancelaciones

Tiene derecho a desistir de su compra en un plazo de 14 días desde la recepción de su pedido, sin necesidad de justificación. Para ejercer este derecho fácilmente, puede utilizar el enlace "Cancelar mi pedido" que encontrará en el pie de página de cada página o en su cuenta de Fruugo, en la sección "Pedidos". Una vez que ejerza su derecho de desistimiento, le enviaremos un correo electrónico de confirmación. Si su pedido ya ha sido enviado por el vendedor, le facilitaremos las instrucciones de devolución necesarias para garantizar que su reembolso se procese rápidamente.

Ver política de cancelación completa