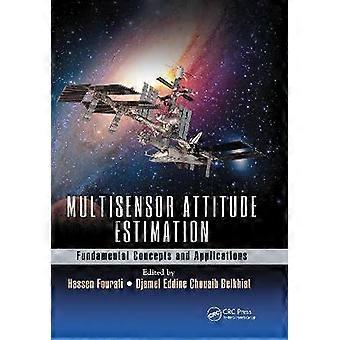
Multisensor Attitude Estimation

209,00 €
+ 5,99 € Envío

Multisensor Attitude Estimation
Vendido por:

209,00 €

En existencias
+ 5,99 € Envío

Política de devoluciones de 14 días

Protección al comprador

Métodos de pago:

  • Marca: Unbranded

Detalles del producto

Detalles del producto

Multisensor Attitude Estimation

There has been an increasing interest in multi-disciplinary research on multisensor attitude estimation technology driven by its versatility and diverse areas of application such as sensor networks robotics navigation video biomedicine etc. Attitude estimation consists of the determination of rigid bodiesâ orientation in 3D space. This research area is a multilevel multifaceted process handling the automatic association correlation estimation and combination of data and information from several sources. Data fusion for attitude estimation is motivated by several issues and problems such as data imperfection data multi-modality data dimensionality processing framework etc. While many of these problems have been identified and heavily investigated no single data fusion algorithm is capable of addressing all the aforementioned challenges. The variety of methods in the literature focus on a subset of these issues to solve which would be determined based on the application in hand. Historically the problem of attitude estimation has been introduced by Grace Wahba in 1965 within the estimate of satellite attitude and aerospace applications. This book intends to provide the reader with both a generic and comprehensive view of contemporary data fusion methodologies for attitude estimation as well as the most recent researches and novel advances on multisensor attitude estimation task. It explores the design of algorithms and architectures benefits and challenging aspects as well as a broad array of disciplines including: navigation robotics biomedicine motion analysis etc. A number of issues that make data fusion for attitude estimation a challenging task and which will be discussed through the different chapters of the book are related to: 1) The nature of sensors and information sources (accelerometer gyroscope magnetometer GPS inclinometer etc. ); 2) The computational ability at the sensors; 3) The theoretical developments and convergence proofs; 4) The system architecture computational resources fusion level. . Language: English
  • Marca: Unbranded
  • Categoría: Educación
  • Idioma: English
  • Fecha de publicación: 2020/09/30
  • Editor / Marca: CRC Press
  • Formato: Paperback
  • Nº de Fruugo : 337363073-740990706
  • ISBN: 9780367655815
Promesa

Garantía del vendedor

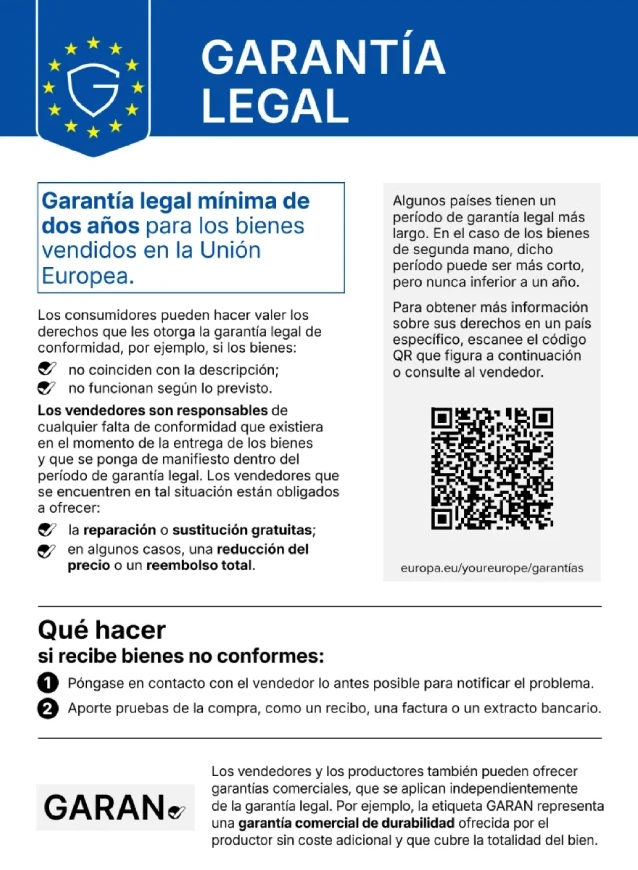
Garantía legal de 2 años incluida

Tus derechos como consumidor en la UE incluyen una garantía legal mínima gratuita de 2 años

Descargar garantía legal de conformidad
Entrega

Entrega

Enviado en un plazo de 5 días

  • STANDARD: 7,99 € - Entrega entre mié 11 noviembre 2026–lun 16 noviembre 2026

Envío desde Reino Unido.

Devoluciones

Devoluciones y cancelaciones

Devoluciones

Hacemos todo lo posible para asegurarnos de que se le entreguen los productos que pida en su totalidad y de acuerdo con sus especificaciones. Sin embargo, si recibe un pedido incompleto o artículos diferentes a los que pidió, o hay alguna otra razón por la que no está satisfecho con el pedido, puede devolver el mismo o cualquier producto incluido en él y obtener un reembolso completo por los artículos.

Vea la política de devolución completa

Cancelaciones

Tiene derecho a desistir de su compra en un plazo de 14 días desde la recepción de su pedido, sin necesidad de justificación. Para ejercer este derecho fácilmente, puede utilizar el enlace "Cancelar mi pedido" que encontrará en el pie de página de cada página o en su cuenta de Fruugo, en la sección "Pedidos". Una vez que ejerza su derecho de desistimiento, le enviaremos un correo electrónico de confirmación. Si su pedido ya ha sido enviado por el vendedor, le facilitaremos las instrucciones de devolución necesarias para garantizar que su reembolso se procese rápidamente.

Ver política de cancelación completa